Autoscaling Controller · View 05 of 37 · 2 · Structure
The decision
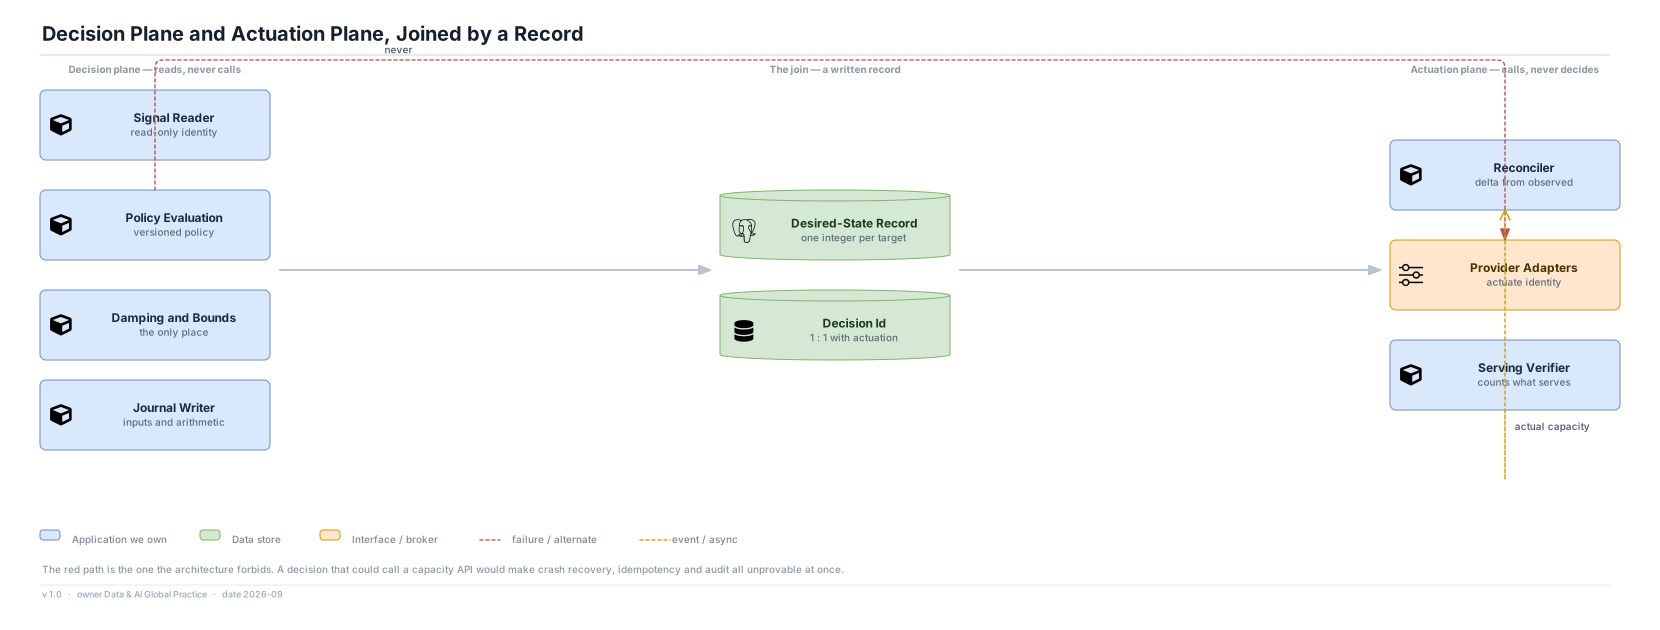
- Decision plane ≠ actuation plane, joined only by a durable desired-state record.
- The decision plane reads signals, evaluates policy, damps, clamps, and writes one number with the reasoning that produced it.
- The actuation plane reads that number, observes what is serving, and converges the two. It holds no policy and no thresholds.
What follows from it
- A crash mid-decision loses nothing: the fleet holds its last declaration and reconciliation resumes.
- Partial failures and lost responses converge instead of compounding, because the delta is re-derived from observed actual capacity.
- Oscillation, hysteresis and rate-limit logic has exactly one place to live and one place to be audited.
- Every capacity change in the fleet's history is explainable from a written record rather than reconstructed from metrics.
The cost
- One extra durable write on the critical path, budgeted at p99 2 s for the decision and 3 s to first actuation call.
- Two components to operate rather than one, and a state store whose availability is now an availability dependency of the fleet's ability to change size — though not of the fleet's ability to serve.